Tuesday, May 27, 2014

Python and Unhappiness :(

This morning you woke up and started to work on organizing the code for the project. You first organized the sensor code, finding the best possible way to send the sensor data. You organized the strings into an easily readable format. After working on the code for a few hours, you went into town to find out about renting space at the middle school. Unfortunately, it was very expensive...On the way back home you stopped at the bank and checked the company balance (which was higher than you had anticipated).

After returning home, you continued to work on the code. You stopped for a quick lunch break at around 11:00. Josef then came over. You worked with him on finally getting to server/client python/java pair working and controlling a motor! After putting the right delay in the code (.75 seconds) the motors seemed to react almost flawlessly!

After finishing with the motors you headed to swimming at 16:00. After swimming you ate a TON because you were very hungry from not eating much during the day.

After swimming you worked more on fixing the code. You were trying to send data earlier in the day, but it had not worked. This was due to many different problems...after 3 jour hours of problem solving you finally fixed most of it. That was NO fun at all. Below is a funny picture you used to cheer yourself up.


Baxter for 3D printing

You had a pretty good day today. You woke up around 0800 again and then headed over to Travis's. While there you made sure that the whole Hobbyking order was ready to go down to Baxter (meaning you tested motor controllers).

You then went to Baxter with Liam and worked on the camera structure. You ended up having to make it much more rigorous and held together in more places (as you broke it into more pieces). You spent almost two hours reworking the design and getting it ready to 3D print.

You then had to export all the SolidWorks files as .stl files so that the printer could use them. After getting the parts all ready you had Mr. Amory start the 3D printer. It seemed to be working well so you went and looked at the through holes. Turns our you need to modify the G-code a little so that they print better.

After that you went back to the computer lab and started work on heat-sinks. You then headed back to Freeport for frisbee, which was unfortunately cancelled due to the weather. So, instead, you went back to Travis's and worked on a couple miscellaneous things.

Then you returned to your house and worked on the heat-sinks even more. You then ate a quick dinner and headed to the Performing Arts awards (as you were part of the musical this year). After returning home you fine tuned the heat-sinks and once again arrived at a possible solution.

Monday, May 26, 2014

Miscellaneous

You woke up at 0800 again today. You then had pancakes made by your father and then you accompanied him to work so that you could grab his ethernet crimpers. You then headed to Travis's around 0930 and created four ethernet cables using the crimpers (it was much easier than using a hammer/screwdriver like the first attempt).

After that you went in town to find accessories for your prom tux and were quite unsuccessful. You then headed back to Travis's and wrote up the beginnings of two blog posts.

After that you tried to look into the problem of getting a dimmer for our LEDs working. It was unsuccessful at the time but Travis figured out the problem tonight. You then ate lunch and played darts for a break.

You helped Josef and Travis with code for the motors using the X-Box controller for about an hour. Then Liam and Josef left (around 1700) and you and Travis decided to work on the float. You two went to L.L.Bean where you bought a waterproof box for the electronics on the float (it took two tries as the rejected your check?).

The two of you then went back to your house and worked on putting the electronics neatly in the box and making a shelf for it to rest on. After that you made a rest for the battery and decided how you would attach the dish.

Finally you bough the accessories for your tux online and started a job search for the summer.

Comin' Together

To you, today seemed to have been more productive than the weekend was. You woke up around 08:45, took a shower, and tried to get the N-Channel MOSFET (metal oxide semiconductor field effect transistor) working. You wired it up and attached it to the Pi, but, while using servo-blaster, the voltage coming from the MOSFET (which should have been varying from 0v to 12v) only varied from 11v to 12v. After you tried different duty cycles and pulse widths on servo-blaster, you decided to go downstairs and crimp the ethernet cables with Nick (who had arrived around 09:45). Using ethernet wire crimpers, you and Nick made all of the ethernet cables for the project and found out that  we need a switch to handle the ethernet traffic of the multiple devices on the network. 

After hooking up the ethernet cables, Nick headed into town and you ate lunch. After lunch you did some research on MOSFETs and were continually puzzled why your setup had not worked. You started to again work on the python code for the project. Liam arrived and wrote up a 3-page documentation of the project so far. Josef then arrived and began working on the code. 

You, Josef, and Nick then decided on how to use the Xbox controller to drive the submersible. You and Josef then decided on the format in which to send the strings used to communicate with the Pi's. After deciding this, you wrote software that would act as a "middle-man" for the motor data. Basically, the BeagleBone on the float is going to handle all of the interacting with the OCU. It will receive the motor data and then act as a client and connect with the Raspberry Pi on the sub. After getting the "middle-man" software done you worked on the Pi's software. Although this wasn't very difficult, you ran into a few problems. Namely, when the code was not working instead of spitting our errors it just sat there...arg. You had to comb through the code looking for your errors. Finally, around 17:00 you had the motor-code working. 

Around that time Josef and Liam had to go to a family party (they were actually late as the party started at 17:00 and they left my house at 17:15....). You and Nick then decided to finish the float. You went to LL Bean and bought a waterproof contained to fit all of the electronics. You then went to Nick's and added mounts for the battery, electronics, and communication disk. You worked on cutting wire for the electronics and trying to fit everything inside of the waterproofed container. 

After having a very good Egg Roll dinner at Nick's, you headed home. At home you had ice cream, test the Ubiquiti power sources on DC power (which did not work), and then returned to the MOSFET. This time you tried the Arduino (which worked) and then decided to use the GPIO.RPi library to run PWM on the Pi rather than servo blaster. It worked like a charm. Below is a video of the LED pulsing: 


Everything seems to finally be coming together. 

Sunday, May 25, 2014

Electronic boxes and shelves

Today you were able to get a lot done, and as it was more productive you were more optimistic about the project…

You went to Travis's at 0900 again and worked on the CAD models that you have been making the last couple days. After finishing all the parts for the heat sinks you worked on creating shelves and boxes for the embedded Linux controllers. 

You then ate lunch (leftover pizza) and played a little frisbee to get some fresh air and a break from the computer from about 1245 to 1330. You then finished the shelving and the boxes to epoxy the Raspberry Pi and BeagleBone in. You then made all the pieces so that they could either be 3D printed or cut out on the 3-axis router.

You then cut out part of the float to make sure you could easily fit the batteries into it. After that you programmed motor controllers to send down to Baxter so they can finish the thrusters. Then you headed home around 1845. 

Finally you tried on the tux that you Grandfather gave you and were happy to find that it fit really well.

Weekend 3: ECE

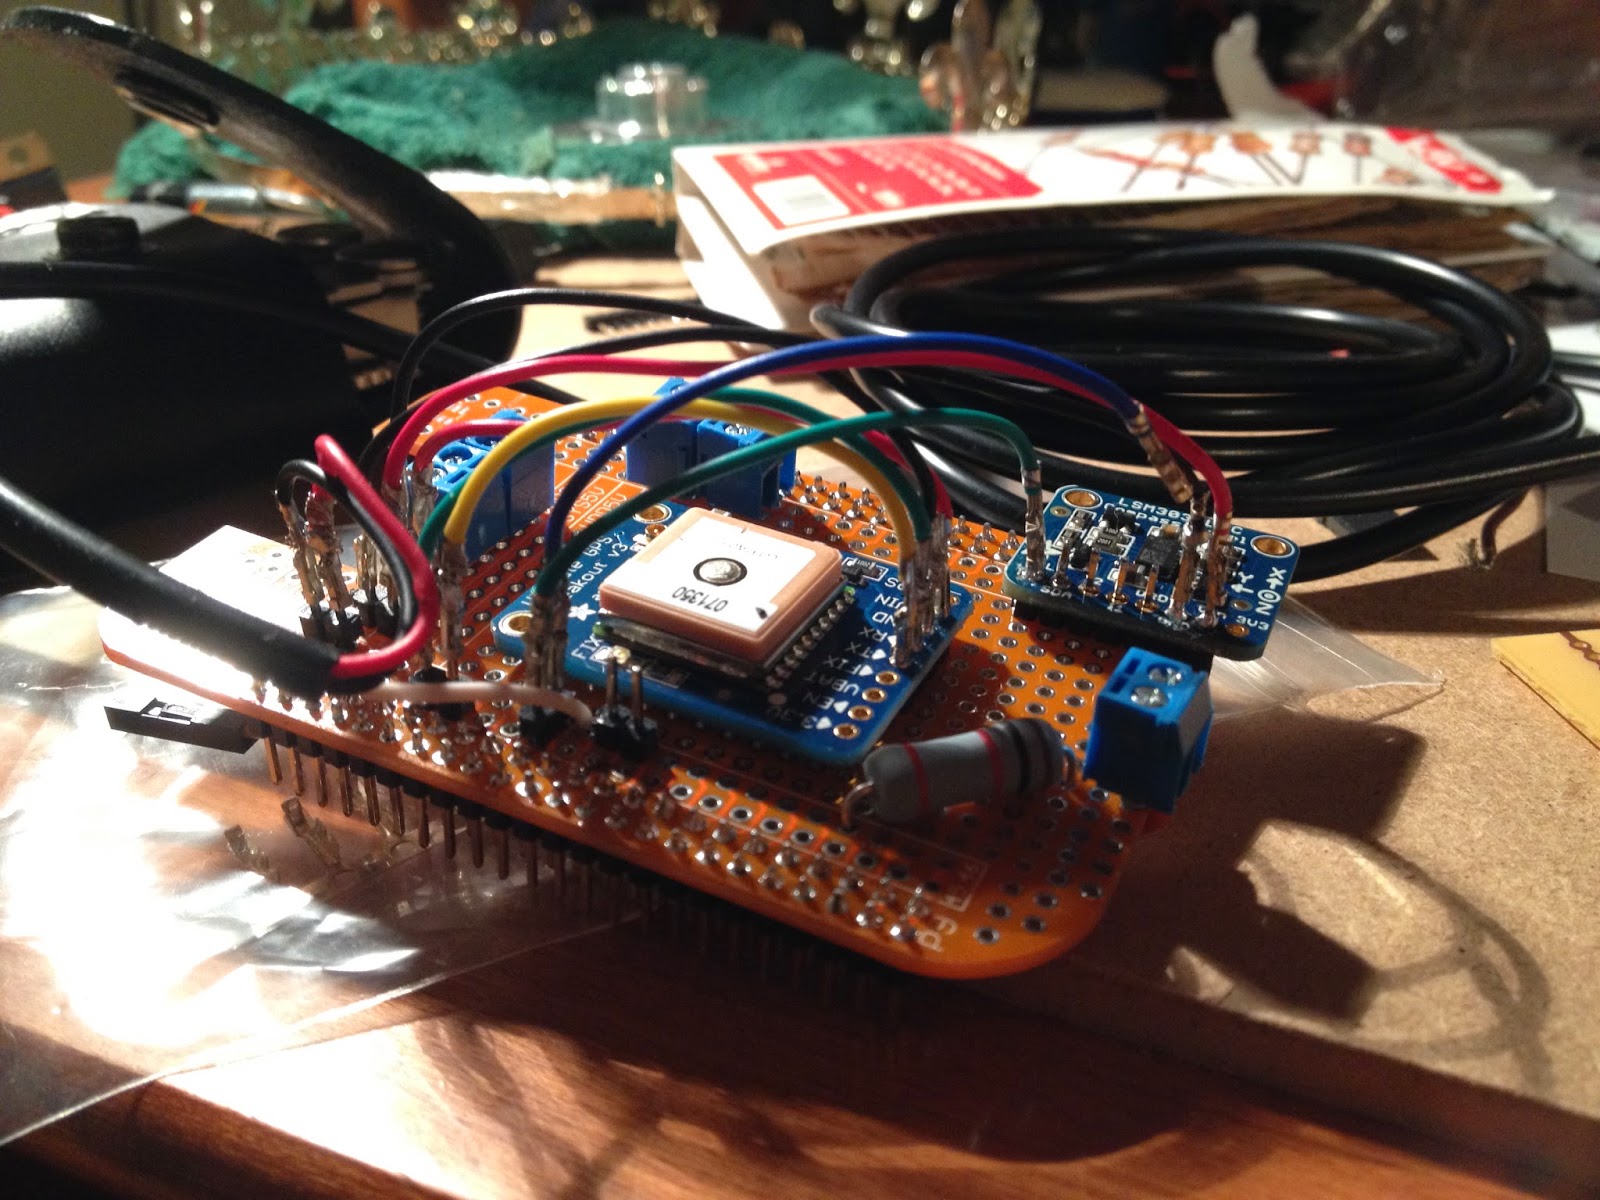
Today you again woke up at 8:25 (predictable...right?) and took a shower. You started work on the Cape for the BeagleBone on the float. At around 9:10 you went down to have breakfast. Liam and Nick were at your house, but your dad had not finished making the pancakes he had wanted to make. You, Liam, and Nick then waited and talked a little, but mostly ate pancakes. At 9:50 Liam and Nick headed downstairs while you headed upstairs to finish the Cape.

Although you went downstairs a few times, you spent almost four hours planning and putting together the cape (you don't know why this took so long...). Below is the finished product with all of the sensors attached:


After finishing the Cape you continued to work on the BeagleBone software. You now have running code which will read the sensor data from ALL of the sensors and output it in a byte stream to a client. It was exciting to finally get some pieces put together. 

Tomorrow you are going to work on the Pi software...basically creating servers to read incoming Xbox data and interpret it -- whether it's the PWM for thrusters, servo, or LEDs.

Saturday, May 24, 2014

Weekend 3: Another Day

Today you woke up at 08:25 without an alarm...you were ready to work on the project! Everybody met at your house at 09:00 (although Josef showed up around 11:00) for another long day. You spend the first half of the morning trying to get the tilt-compensated compass working via I2C on the BeagleBone. After much failing, it continued no to work. You decided to started working on finishing the python code.

You consolidated many of the different sensor reading programs into a single python module. You then tweaked the old RoboGoby Servers in order to allow data to be sent and received continuously.

You also ordered pieces for the project, which you had picked out the evening before. You also finished writing a blog post on the DS18B20 temperature sensor on the BeagleBone Black.

At around 18:45 Liam, Josef, and Nick headed over to Liam's house for dinner. You headed to what you thought was a swim team BBQ, although you were given the wrong date...the BBQ will actually be tomorrow.

You then headed back to Liam's house to eat and then to yours. You wrote some emails (for frisbee and the summer camp your running) and then Nick and you talked about different options for the spinning disk on the float. You also planned out tomorrow which will include going to Home Depot, finishing up the electronics on the float, and hopefully finishing up some CAD modeling.

After Nick left you started working on the BeagleBone Cape: